
A drone's radio link is its lifeline, and antenna orientation is the link's weakest variable: as the aircraft banks, pitches, and yaws, the antenna's radiation pattern rotates with it, creating nulls and fades that drop packets at the worst moments. Antenna diversity, using two antennas with different orientations and switching to whichever receives better, is the standard defense. On ESP32-based drone nodes, implementing diversity means understanding the chip's radio behavior, the switching mechanism, and the physical antenna arrangement that makes diversity actually diverse.
Why One Antenna Is Not Enough
Every antenna has directional characteristics: even a nominally omnidirectional antenna has nulls, directions of weak reception, and the drone's own frame, battery, and electronics shadow parts of the pattern. In flight, the aircraft's attitude constantly changes which directions those nulls point, so a single antenna experiences periodic fades as nulls sweep across the ground station's direction. These fades cause packet loss, control latency spikes, and in the worst case, failsafe triggers.
Diversity defeats this statistically: two antennas with different orientations rarely fade simultaneously, because their nulls point in different directions. The system monitors both and uses the stronger signal, turning deep fades into minor dips. The improvement is not subtle; diversity is often the difference between a solid link and an unreliable one.
ESP32 Radio and Antenna Options
The ESP32's radio supports external antennas on modules that provide the antenna connector or pad, and its Wi-Fi/Bluetooth radio can work with switched antenna configurations. True hardware diversity switching, where the RF front end rapidly selects between antennas per packet, requires RF switch components and control logic; the ESP32 does not include this natively on most modules, so diversity is typically implemented at the system level rather than inside the chip.
The practical implementations range from simple to sophisticated: two ESP32 radios (or two radio modules) each with its own antenna, with the firmware selecting the better link; a single radio with an RF switch toggling between antennas under firmware control; or at the simplest, two antennas combined through a passive network (which is not true diversity but improves the pattern somewhat). The firmware-controlled switch is the sweet spot for most drone nodes.
Physical Antenna Placement
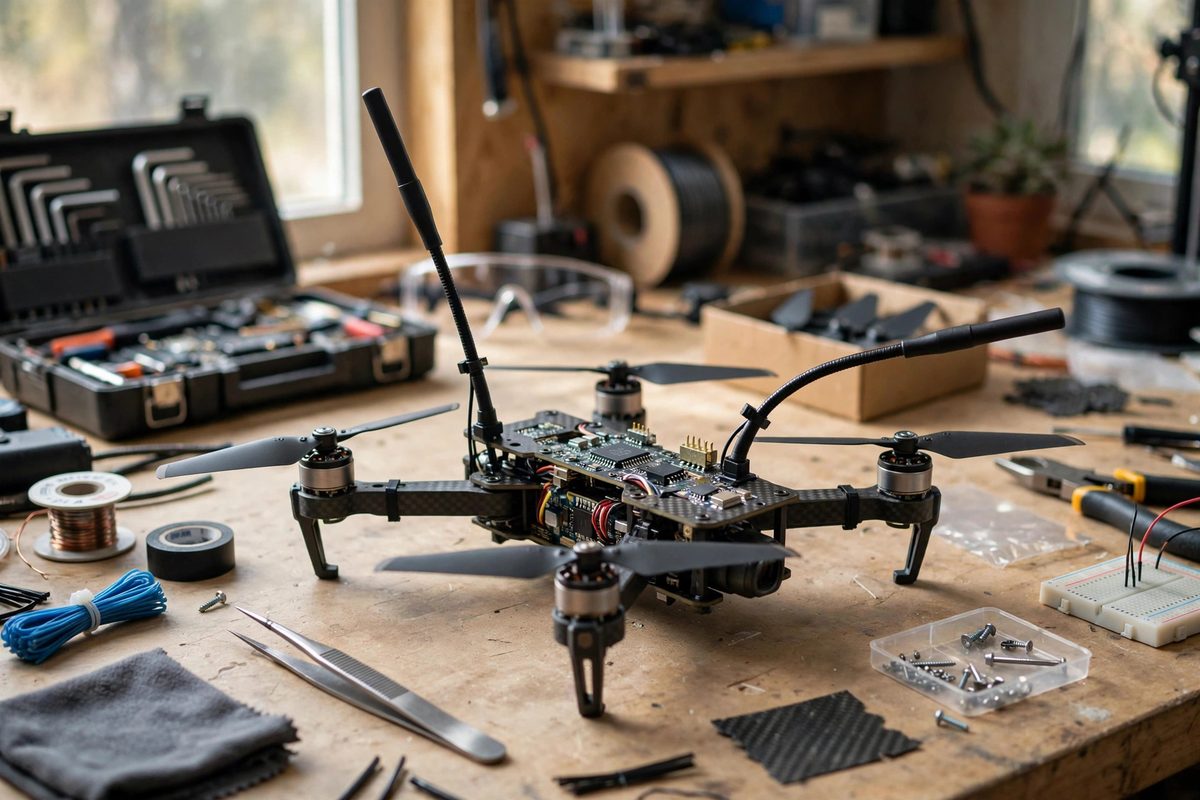
Diversity only works if the antennas are actually diverse: separated in space, oriented differently, or both. Mount the two antennas at roughly ninety degrees to each other (one vertical, one horizontal is the classic arrangement) and separate them by at least a quarter wavelength where the airframe allows. Keep them clear of the battery, motors, and carbon fiber structure, all of which detune and shadow antennas.
- Orient antennas away from the airframe's conductive mass; carbon fiber is effectively a radio shield.
- Keep antenna feedlines short; long coax at 2.4 GHz loses significant signal.
- Secure antennas against vibration; a flopping antenna's pattern flaps with it.
- Test the pattern on the ground by rotating the aircraft and watching signal strength.
Switching Logic in Firmware
The firmware monitors signal quality, typically RSSI (received signal strength) on each antenna path, and selects the better one. The switching should include hysteresis: require the alternate antenna to be clearly better (by several dB) before switching, and hold the switch for a minimum time, to prevent rapid oscillation between antennas when their signals are nearly equal. Oscillation is worse than a mediocre choice; it disrupts the link continuously.
Switch during packet gaps where possible, not mid-packet; switching the RF path during reception corrupts the in-flight packet. The firmware's radio driver usually provides hooks or timing information for clean switching points. This is a detail that separates working diversity from diversity that causes the dropouts it was meant to prevent.
Testing and Validation
Validate diversity with range tests comparing single-antenna and diversity configurations along the same flight path. Log RSSI from both antennas and the switching decisions; the logs reveal whether diversity is engaging when it should and whether the switching thresholds are set sensibly. Ground-based pattern testing, rotating the aircraft through all attitudes while monitoring, characterizes the installation before it ever flies.
Watch for the diversity system masking a bad installation: if one antenna is badly placed and the system always selects the other, you have single-antenna reliability with diversity complexity. Both antennas should contribute meaningfully across the flight envelope; if the logs show one antenna never winning, fix the installation, not the algorithm.
Separate the antennas, orient them differently, switch with hysteresis, and validate with logs. Diversity is probability engineering: two imperfect antennas, wisely combined, produce a link far more reliable than either alone.
Related Guides
- FreeRTOS Task Pinning for Low Latency ESP32 RC: An ESP32 remote-control link lives or dies on latency: the delay between moving the stick and the servo responding. The ESP32 has two CPU cores, but
- ESP-NOW Packet Latency on Remote Systems: ESP-NOW is Espressif's connectionless Wi-Fi protocol for direct device-to-device communication, and its headline feature is low latency: no
- Packet Serialization Rates in ESP-NOW Long Range: ESP-NOW's long-range mode trades speed for reach, and that trade shows up directly in how fast you can serialize and send packets. A remote control
- Heartbeat Failsafe Timing for ESP-NOW Controllers: ESP-NOW makes ESP32 boards talk to each other directly, fast, and without a router, which makes it ideal for remote control: a handheld controller