
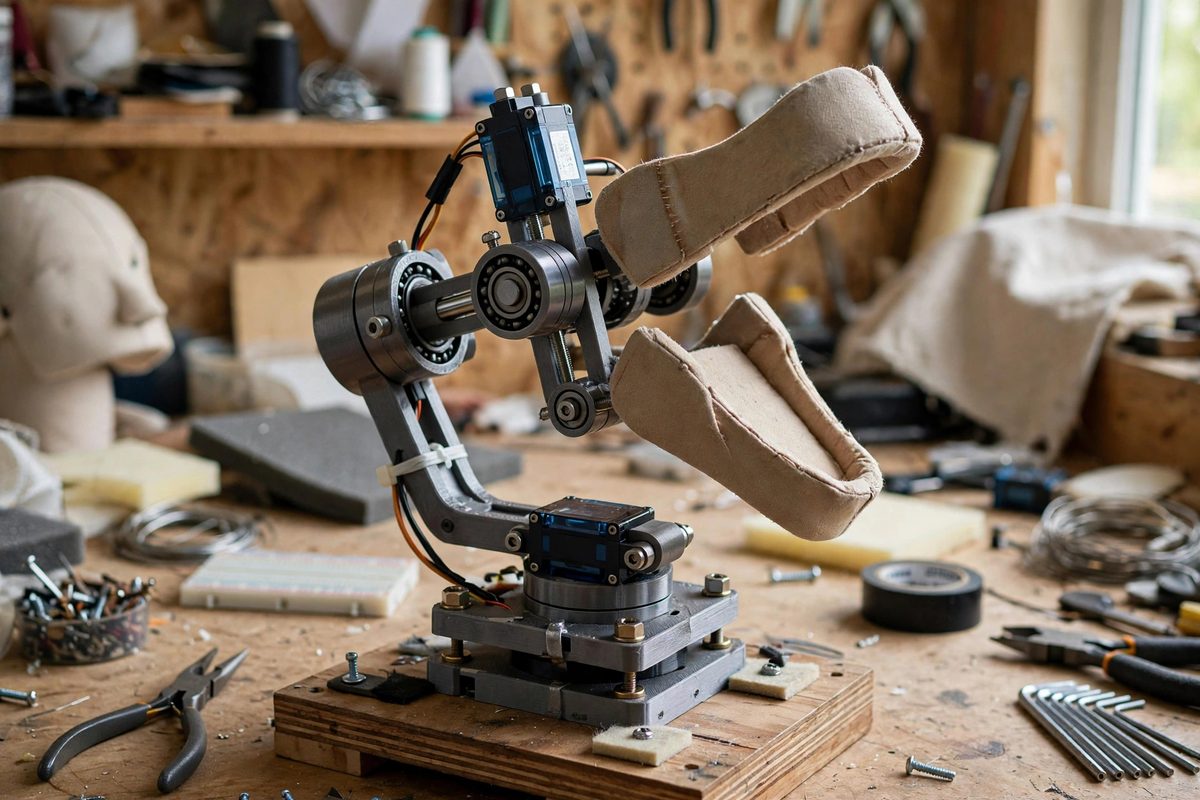
A puppet jaw that just flaps open and shut reads as a puppet. A jaw that opens, shifts slightly sideways, and settles with a hint of asymmetry reads as alive. Dual servo gimbal geometries give the jaw two axes of motion, typically open-close plus a lateral or pitch trim, and the geometry of how those servos connect to the jaw determines whether the motion looks mechanical or natural.
Why Two Servos Instead of One
A single servo drives the jaw along one fixed arc, which is fine for simple talking but produces the same motion every time. Adding a second servo on a different axis lets the jaw move in a plane rather than along a line: open-close combined with a slight side shift, or open-close with independent control of the jaw's front versus back. The second axis does not need large travel; a few degrees of lateral motion layered over the main open-close movement is enough to break the mechanical repetition. The audience cannot name what changed, but they feel the difference between a hinge and a mouth.
Gimbal Geometry Basics
The classic arrangement mounts the jaw on a pivot for the open-close axis, and mounts that whole pivot assembly on a second pivot for the lateral axis. Each servo drives one pivot through a linkage. The order matters: the outer gimbal axis carries the inner one, so the outer servo and its mount must handle the weight and inertia of everything inside. Keep the moving mass low by building the jaw and inner gimbal from light materials; the servos then work well within their torque ratings and the motion stays crisp instead of laggy. Slop in either pivot shows up directly as wobble, so use bearings or tight-fitting pivots rather than screws through oversized holes.
Linkage Design and Servo Placement
Place the servos where their weight helps balance the head, typically low and toward the back, and run linkages forward to the jaw pivots. Short, stiff linkages with ball ends transmit motion accurately; long flexible pushrods absorb the small movements that make the motion lifelike. Set the linkage geometry so the servo's mid-travel corresponds to the jaw's rest position, giving equal travel in both directions and keeping the servo in its strongest, most linear range. Avoid linkages that approach toggle or over-center positions, where small servo movements produce huge jaw jumps or the mechanism locks.
Programming Natural Motion
The geometry enables lifelike motion but the programming delivers it. Drive the main open-close servo from the dialogue or performance input, and add small amounts of the secondary axis motion: a slight lateral offset that varies with the "effort" of the speech, a tiny pitch change on emphasized syllables. Randomize the secondary motion subtly so no two jaw movements are identical. Ease the servo motion with acceleration curves rather than snapping between positions; real jaws accelerate and decelerate, and the eye reads constant-velocity motion as robotic instantly.
Power and Reliability
Two servos working a jaw draw meaningful current in spikes, especially when the jaw changes direction quickly. Power them from a supply that handles the stall current of both servos together, not just the running current, or the voltage will sag and the motion will stutter at the worst moments. Keep the servo power separate from sensitive electronics like radio receivers or audio circuits to avoid glitches. In a performance puppet, build in a manual override or a safe rest position; if a servo fails mid-show, the jaw should fail closed and neutral, not locked open.
Lifelike jaw motion is geometry plus programming: two clean pivot axes, stiff short linkages, servos placed for balance, and motion code that layers subtle secondary movement over the main open-close drive. Build the mechanism tight, program it loose, and the puppet starts talking instead of flapping.
Related Guides
- Dual Servo Gimbal Geometries for Animatronic Eyelids: Animatronic eyelids sell the illusion of life more than any other single mechanism: a blink is the gesture audiences read as consciousness. A
- Dual-Axis Gimbal Geometries for Animatronic Eye Blinks: An animatronic eye that can look around needs two axes of rotation, pan and tilt, and a blink mechanism on top of that. The geometry of how those
- Servo Cable Tension Geometry for Animatronic Jaws: An animatronic jaw looks simple until you build one: a hinged lower jaw, a servo, and a cable connecting them. Then you discover that the jaw either
- Bowden Cable Routing for Compact Eyeball Servos: Animatronic puppet eyes need to move fast, precisely, and in a tiny space, but servos are bulky and their vibration shows in the performance. Bowden