
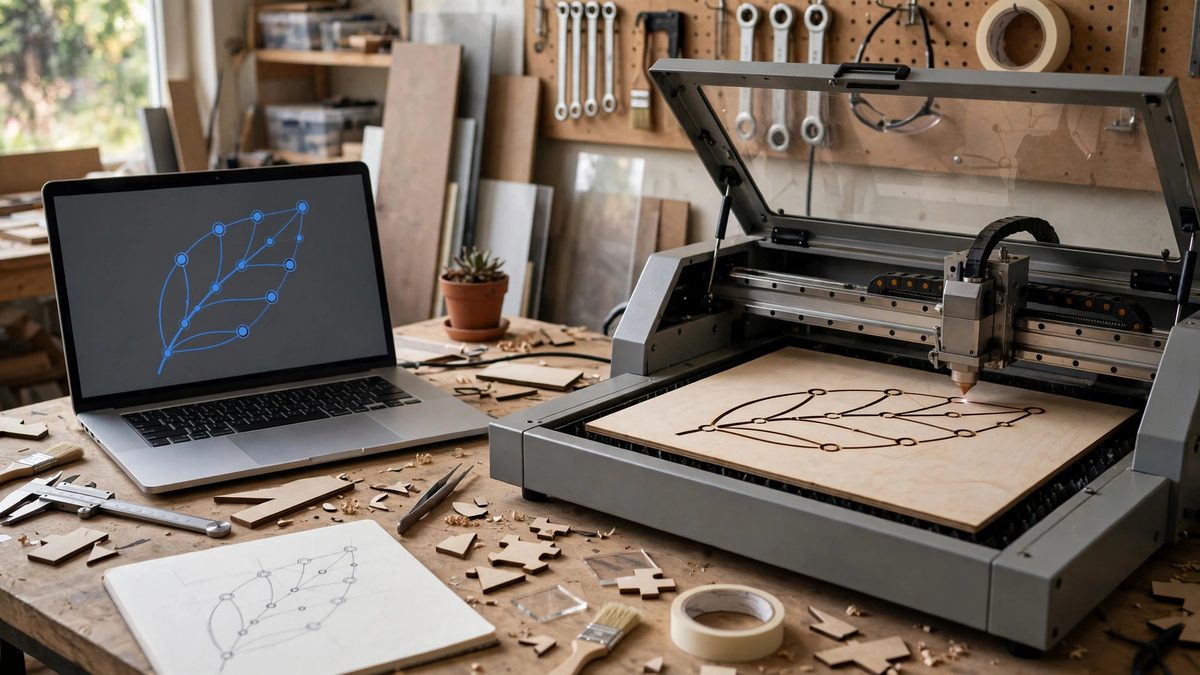
A laser cutter's speed is not just the speed setting in the software; it is also the geometry of the vector file. Every node in a path is a point where the motion system must decide what to do: accelerate, decelerate, change direction. Dense, messy node structures force the machine into constant micro-adjustments that slow the effective cutting speed far below the programmed feed rate, while clean, optimized paths let the machine run at full speed. Node optimization is free speed, earned in the design file before the laser ever fires.
Why Nodes Slow the Machine
Motion controllers plan moves between nodes, and at each node they evaluate the direction change: a sharp corner requires deceleration to avoid overshoot, while a smooth continuation allows full speed. A path with hundreds of unnecessary nodes is hundreds of deceleration decisions, each costing time. Worse, nodes placed with slight positional jitter, the artifact of auto-tracing or shaky hand drawing, create micro-direction-changes that the controller treats as corners, slowing the head to a crawl on what should be a smooth curve.
The machine's acceleration limits compound this. Even where the controller decides it can maintain speed, the physical gantry must accelerate and decelerate through each segment; short segments between dense nodes never reach programmed speed before the next node demands slowing. The head stutters along at a fraction of its capability, and cut quality suffers too: slow, hesitant motion over-cuts and chars.
Optimization Rules for Speed
The first rule is minimal nodes: a smooth curve needs anchors only at its curvature extremes, with bezier handles doing the rest. The second is smooth nodes: where direction does change, make the transitions tangent-continuous so the controller reads them as flow rather than corners. The third is no duplicates: stacked duplicate nodes, common in auto-traced art, read as zero-length segments that confuse the motion planner and should be deleted.
The fourth rule is path joining: separate path segments that form a continuous cut should be joined into single paths. Every path break is a travel move, a pierce, and a restart; joined paths cut continuously. The time savings on complex designs with hundreds of segments is dramatic.
Cut Order and Travel Optimization
Node optimization pairs with cut ordering: the sequence in which the machine visits the paths. Inside cuts before outside cuts (so the part does not shift before its interior is done), nearby paths grouped to minimize travel, and the travel moves themselves kept short. Most laser software offers automatic path optimization; use it, but verify the result, because the optimizer's priorities (minimum travel) occasionally conflict with physics (inside before outside).
- Simplify auto-traced paths aggressively; tracing routinely produces ten times the needed nodes.
- Convert text to outlines and then simplify; font outlines are node-dense by design.
- Remove hidden and overlapping geometry; the laser cuts what is there, including invisible duplicates.
- Set the optimization to respect cut order constraints; speed means nothing if parts shift mid-job.
Corner Handling at Speed
Sharp corners genuinely require deceleration, and the power must adjust accordingly: a laser dwelling in a corner at full power over-burns it. Power ramping or corner power reduction, where the software lowers power proportional to speed through corners, keeps corner quality consistent at high feed rates. If the software lacks this, the alternative is slightly rounding sharp corners in the design, trading a microscopic geometric change for a large speed gain.
For piercing-heavy designs (fretwork, lattice), the pierce time dominates anyway; node optimization helps less here than minimizing pierce count by joining paths. Know which factor limits your specific job: travel-heavy designs benefit from ordering, pierce-heavy from joining, curve-heavy from node cleanup.
Measuring the Improvement
Time a representative job before and after optimization. The software's time estimate, if available, gives a quick comparison, but the real proof is the clock: optimized files routinely cut 20 to 50 percent faster on complex vector work, with better edge quality as a bonus, since smooth fast motion cuts cleaner than stuttering slow motion.
Make optimization part of the design workflow, not a pre-cut chore. Drawing cleanly from the start, with minimal nodes and joined paths, costs nothing extra and pays on every job. The fastest laser is the one whose file does not make it think.
Minimal nodes, smooth transitions, joined paths, sensible order, and corners handled deliberately. The vector file is the first machine in the chain; optimize it and every machine downstream runs faster.
Related Guides
- Corner Radius Compensation for High Speed Laser Paths: At high cutting speeds, a laser cannot turn a sharp corner without consequence: the motion system must decelerate into the corner and accelerate out
- Kerf Compensation in Vector Offset Paths: Every laser cut removes a strip of material, the kerf, and every part comes out smaller than drawn by half the kerf on each side. For decorative work
- Lead-In and Lead-Out Geometry in Thin Sheet Cuts: Where the laser pierces thin sheet matters as much as where it cuts. A pierce is violent: the beam dwells and the entry point gets more heat than any
- Corner Deceleration Smoothing in Vector Kerf Profiles: A laser cutting a vector corner has a physics problem: the motion system must slow down to change direction, but the beam keeps delivering full power